line_segment_detector
Detects the line segments with the line segment detector (LSD, cv::LineSegmentDetector).
opencv_apps |
3.0.0 and later |
|---|---|
ROS |
ROS One, jazzy, kilted, lyrical and later |
OpenCV |
OpenCV 3.0 - 3.4.5 or 4.5.4 or later, which have cv::createLineSegmentDetector() |
Group |
Features and shapes, the nodes of which publish |
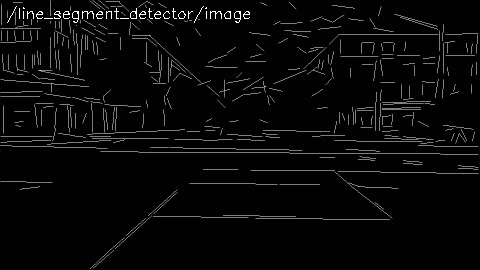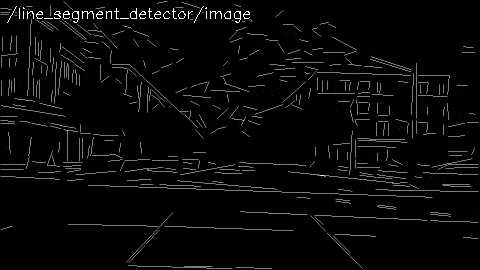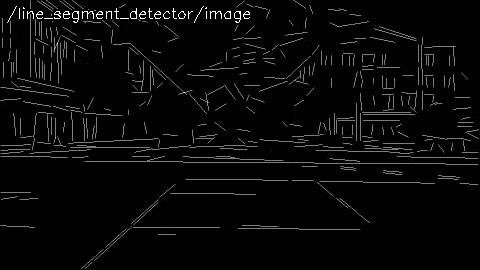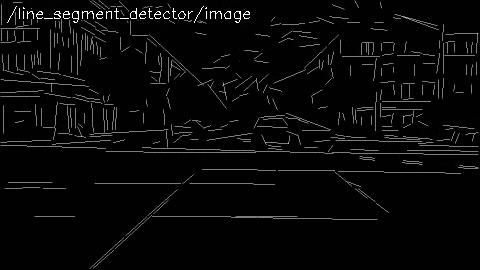
Usage
# ROS 2
ros2 launch opencv_apps line_segment_detector.launch.xml image:=/camera/image_raw debug_view:=false
# ROS 1
roslaunch opencv_apps line_segment_detector.launch image:=/camera/image_raw debug_view:=false
Try it with the demo video
Download the input video of the demo above, publish it as image with image_publisher, and run the node on it, in the terminals:
wget https://ros-perception.github.io/opencv_apps/media/clips/street.mp4
# terminal 1: publish the video as image in a loop
ros2 run image_publisher image_publisher_node street.mp4 --ros-args -p publish_rate:=10.0 -r image_raw:=image
# terminal 2: run the node with the parameters of the demo
ros2 launch opencv_apps line_segment_detector.launch.xml image:=image lsd_density_threshold:=0.3 lsd_line_length_threshold:=10.0 lsd_refine_type:=2 lsd_scale:=0.4
# terminal 3: view the result
ros2 run rqt_image_view rqt_image_view /line_segment_detector/image
In ROS 1:
# terminal 1
rosrun image_publisher image_publisher street.mp4 _publish_rate:=10 __name:=camera
# terminal 2
roslaunch opencv_apps line_segment_detector.launch image:=camera/image_raw lsd_density_threshold:=0.3 lsd_line_length_threshold:=10.0 lsd_refine_type:=2 lsd_scale:=0.4
See Credits of the demo videos for the license of the video.
Subscribed topics
Topic |
Type |
|---|---|
|
|
Published topics
Topic |
Type |
|---|---|
|
|
|
Parameters
See also the common parameters.
Name |
Type |
Default (range) |
Changed at run time |
Description |
|---|---|---|---|---|
|
double |
22.5 (0.1 - 179) |
yes |
Gradient angle tolerance in degrees |
|
double |
0.7 (0 - 0.9) |
yes |
Minimal density of aligned region points in the enclosing rectangle |
|
double |
100.0 (0 - 1000) |
yes |
Threshold of line length. Shorter lines are not published nor drawn. |
|
double |
0.0 (0 - 360) |
yes |
Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen |
|
int |
1024 (1 - 10000) |
yes |
Number of bins in pseudo-ordering of gradient modulus |
|
double |
2.0 (0 - 100) |
yes |
Bound to the quantization error on the gradient norm |
|
int |
0 (0 - 2) |
yes |
Line Segment Detector Modes, 0: REFINE_NONE, 1: REFINE_STD, 2: REFINE_ADV |
|
double |
0.8 (0.1 - 1) |
yes |
The scale of the image that will be used to find the lines. Range [0.1..1] |
|
double |
0.6 (0.1 - 10) |
yes |
Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale |
|
int |
3 |
no, restart the node |
Specify queue_size of input image subscribers |
Source
src/nodelet/line_segment_detector_nodelet.cpp, launch/line_segment_detector.launch.xml