match_template
Finds the template image in the image (cv::matchTemplate()), and publishes the matched regions. The template is given by the ~/template topic, a file, the mouse or the ~/set_roi service.
opencv_apps |
3.0.0 and later |
|---|---|
ROS |
ROS One, jazzy, kilted, lyrical and later |
OpenCV |
OpenCV 3.0 or later |
Group |
Tracking, the nodes of which publish |
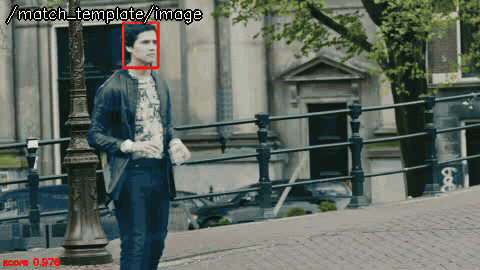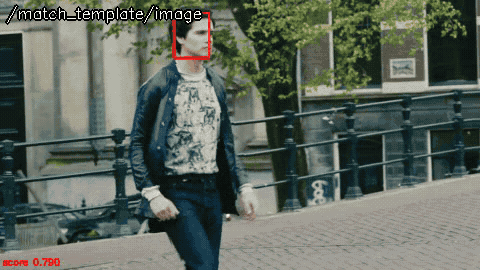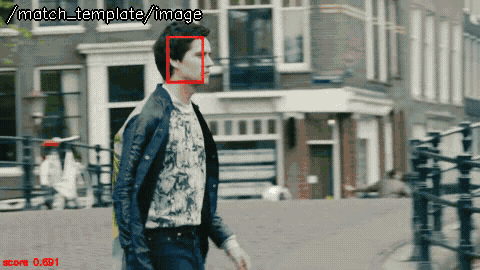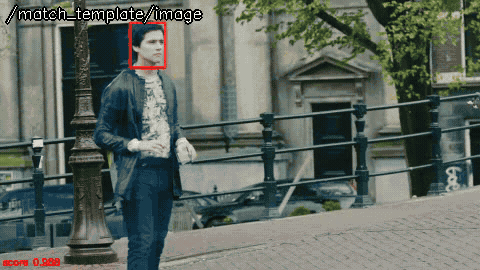
Usage
# ROS 2
ros2 launch opencv_apps match_template.launch.xml image:=/camera/image_raw debug_view:=false
# ROS 1
roslaunch opencv_apps match_template.launch image:=/camera/image_raw debug_view:=false
Try it with the demo video
Download the input video of the demo above, publish it as image with image_publisher, and run the node on it, in the terminals:
wget https://ros-perception.github.io/opencv_apps/media/clips/tos_canal.mp4
ffmpeg -i tos_canal.mp4 -frames:v 1 frame0.png  # the first frame
# terminal 1: publish the video as image in a loop
ros2 run image_publisher image_publisher_node tos_canal.mp4 --ros-args -p publish_rate:=10.0 -r image_raw:=image
# terminal 2: run the node
ros2 launch opencv_apps match_template.launch.xml image:=image
# terminal 3: then run once
ros2 run opencv_apps set_image.py 305 90 70 90 frame0.png --ros-args -r set_roi:=/match_template/set_roi
# terminal 4: view the result
ros2 run rqt_image_view rqt_image_view /match_template/image
Set the face of the man on the first frame with set_image.py just after the video starts (the demo publishes the frames one by one and sets it at the start of each loop).
See Credits of the demo videos for the license of the video.
Subscribed topics
Topic |
Type |
|---|---|
|
|
|
|
|
|
Published topics
Topic |
Type |
|---|---|
|
|
|
|
|
|
|
|
Services
Service |
Type |
|---|---|
|
|
Parameters
See also the common parameters.
Name |
Type |
Default (range) |
Changed at run time |
Description |
|---|---|---|---|---|
|
string |
“” |
yes |
File name of the mask image of the template, non-zero pixels are used |
|
int |
5 (0 - 5) |
yes |
Matching Method, 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED |
|
double |
0.0 (0 - 1) |
yes |
Minimum similarity of a match, the score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED; not used by the methods which are not normalized |
|
int |
1 (1 - 100) |
yes |
Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression |
|
int |
3 |
no, restart the node |
Specify queue_size of input image subscribers |
|
string |
“” |
yes |
File name of the template image |
Source
src/nodelet/match_template_nodelet.cpp, launch/match_template.launch.xml